Correct the binding
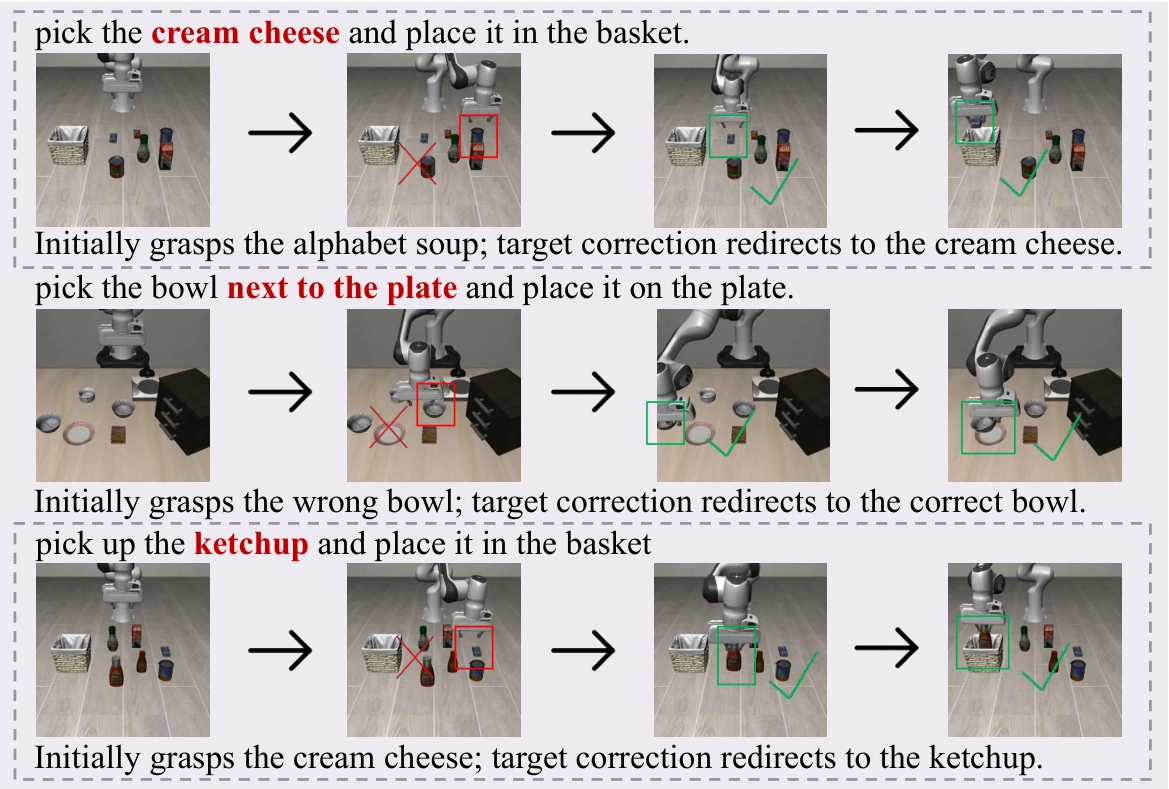
When the language-specified object is uncertain or inconsistent with the scene, rebind the target and regenerate the grounded prompt.
VISION · LANGUAGE · ACTION
Failure-Aware Inference-Time Multi-Agent Control
for Robust VLA Manipulation
Observe the failure. Adapt the control. Continue the task.
Anonymous manuscript · Frozen VLA backbones · Inference-time recovery
FIT-MAC adds failure diagnosis and two complementary recovery paths to a frozen VLA: target rebinding for grounding errors, and local pick-and-place recovery for execution failures.
01 / THE IDEA
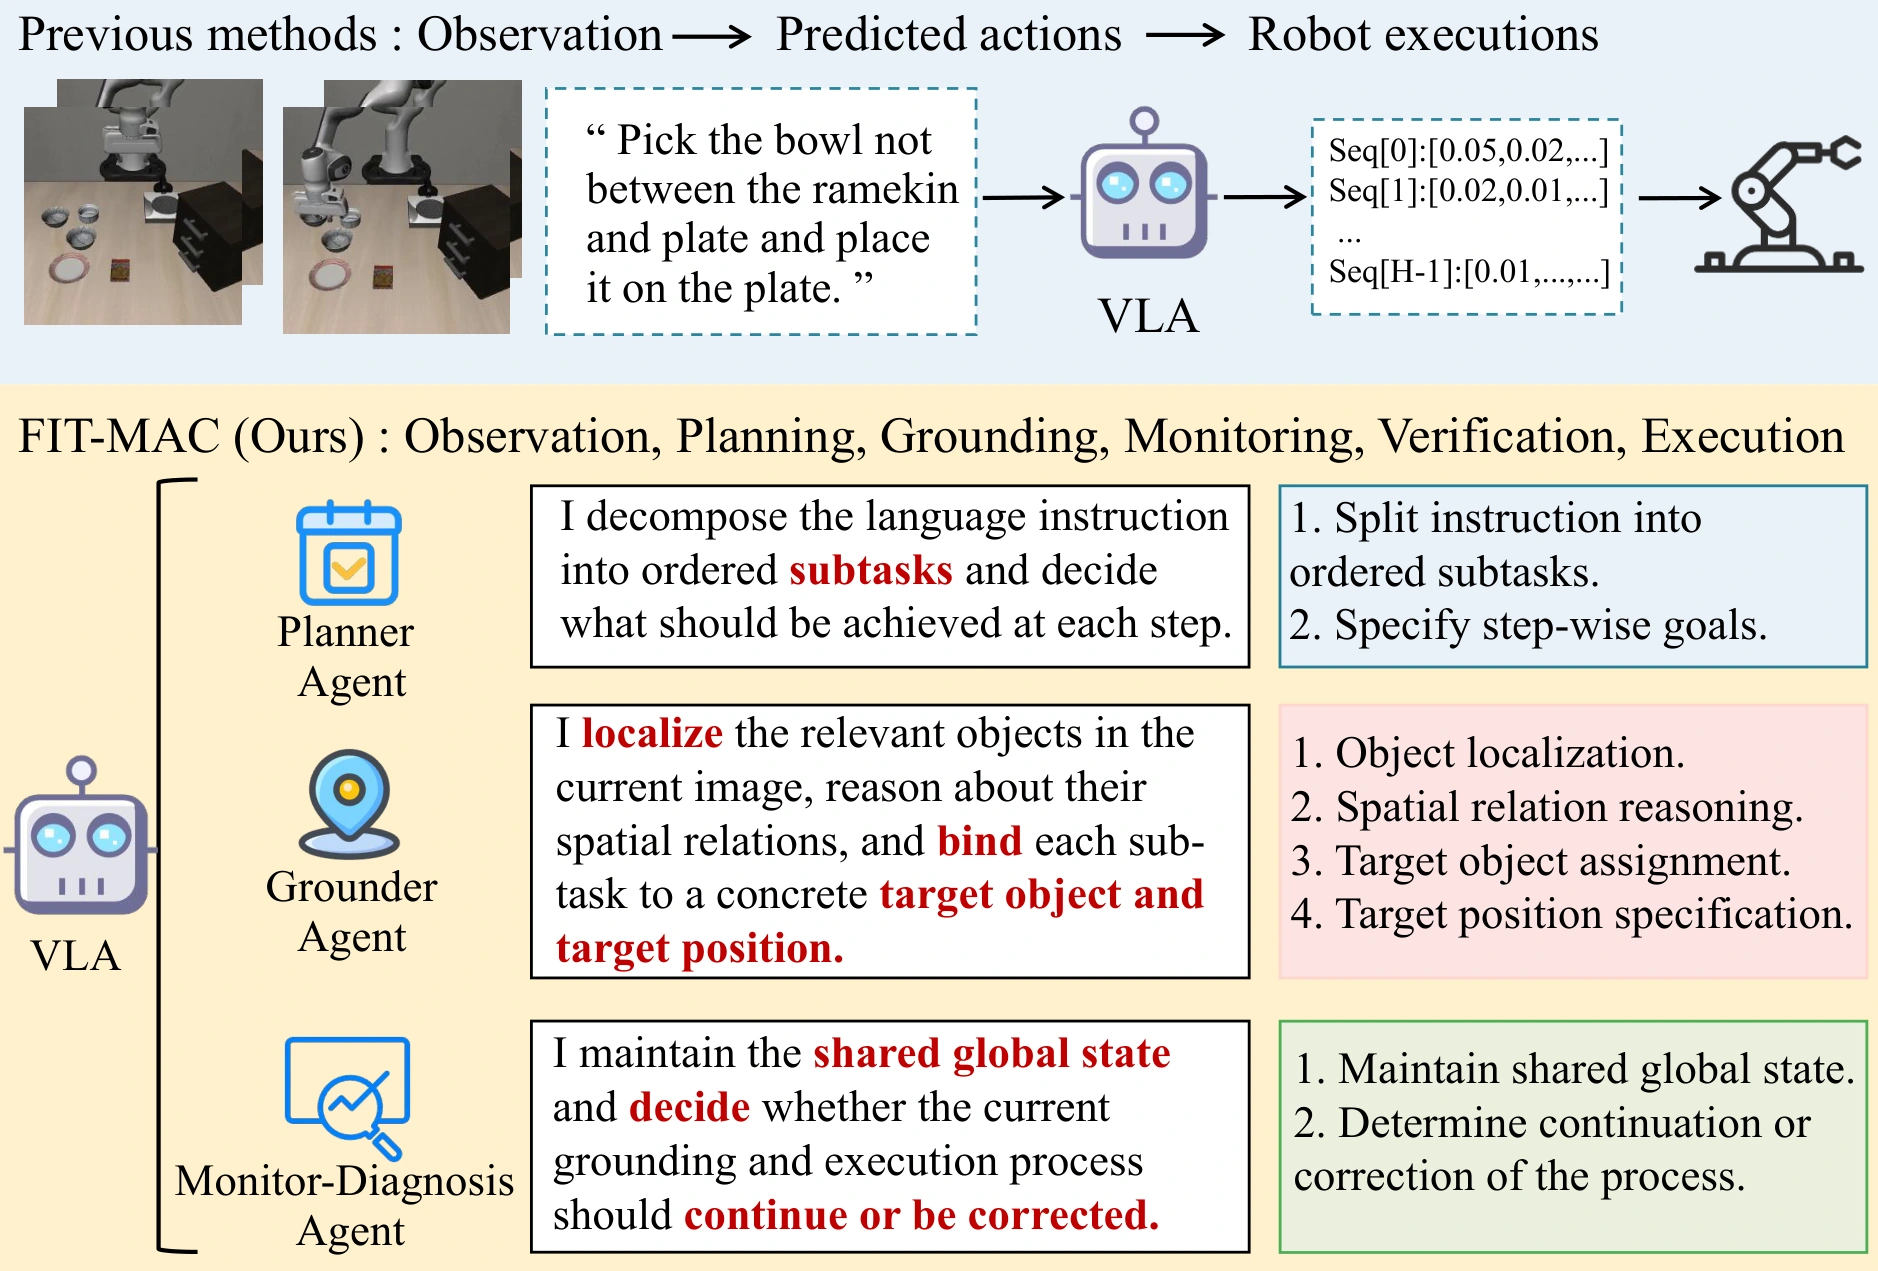
Vision-language-action (VLA) models have achieved strong performance on standard robotic manipulation benchmarks. However, their reliability can degrade substantially when task conditions deviate from the nominal setting. Perturbations in object positions and task instructions may lead to complete task failure. Existing VLA policies generally lack an explicit runtime mechanism for distinguishing these failure modes and selecting an appropriate recovery strategy.
To systematically mitigate this issue, we propose FIT-MAC, a failure-aware inference-time multi-agent control framework for robust VLA manipulation. FIT-MAC augments a frozen VLA policy with an inference-time control layer. First, the Task Planner Agent decomposes the language instruction into an ordered sequence of manipulation subtasks, and the Grounder Agent resolves each instruction-level reference to a visual target. Next, the Monitor-Diagnosis Agent tracks phase-specific execution progress and distinguishes target-binding failures from local execution failures. Finally, FIT-MAC routes each detected failure to a corresponding recovery mechanism, target rebinding for target failures and bounded grasping or placement recovery for execution failures. When no failure is detected, the original VLA remains the default action generator.
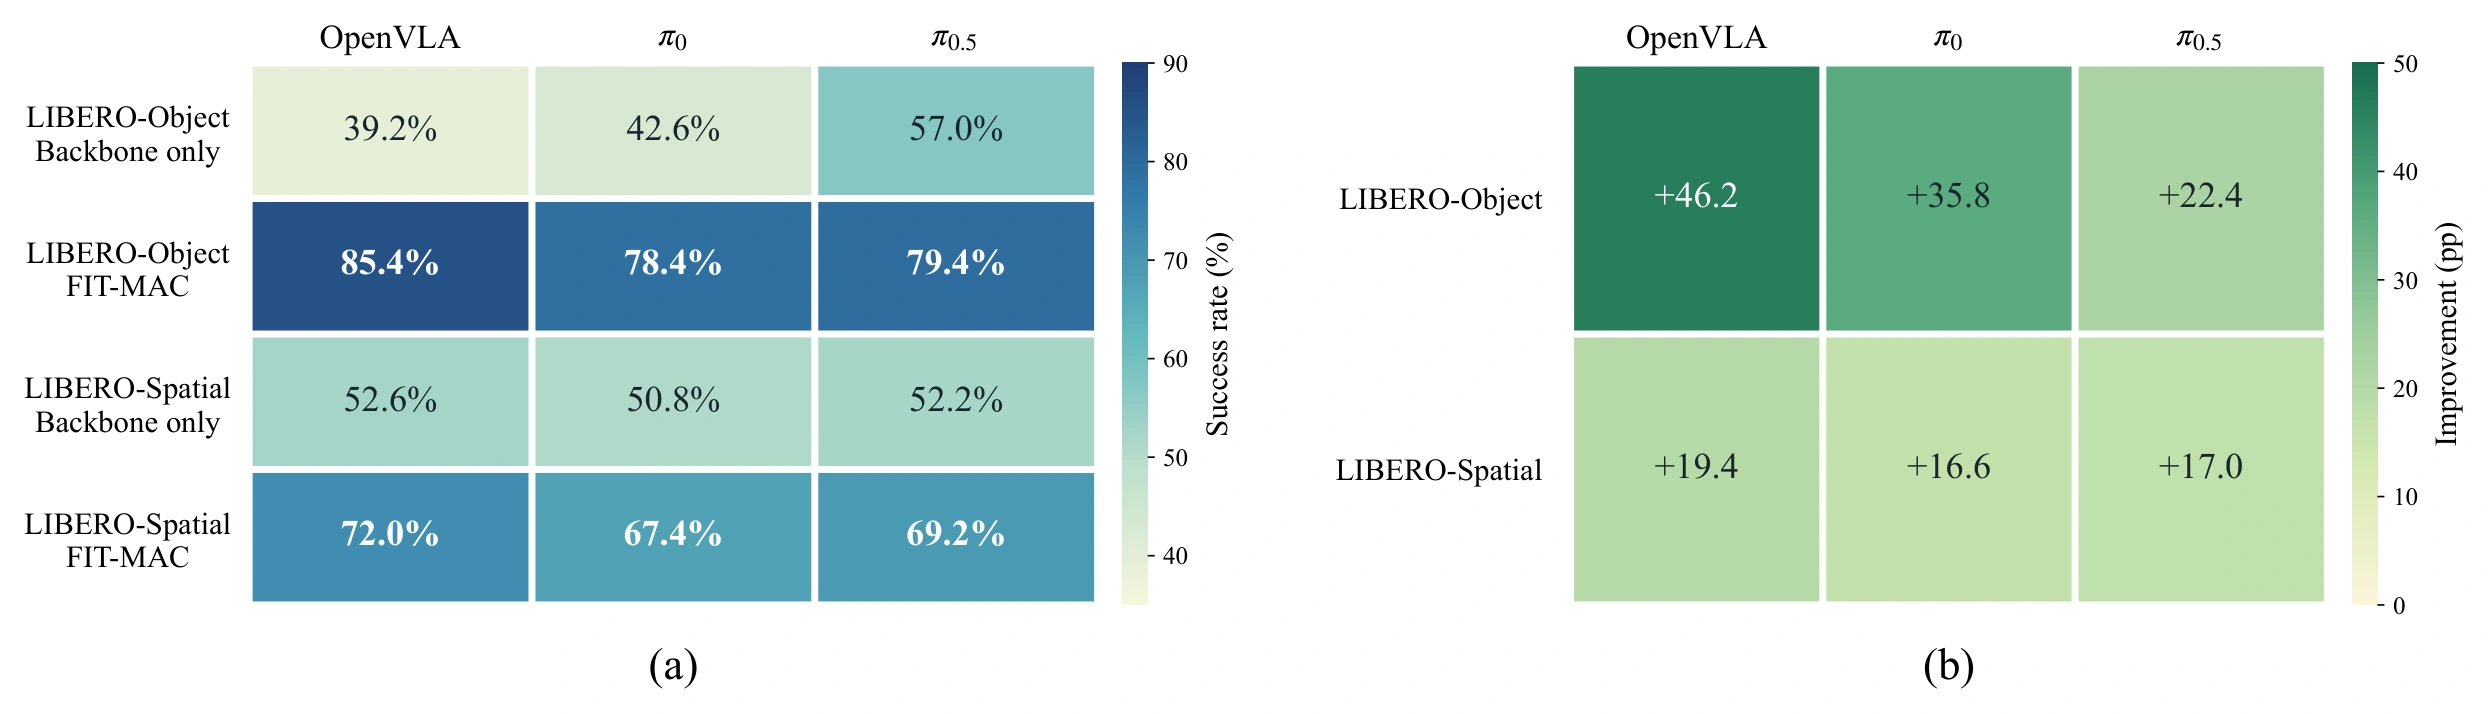
Extensive experiments on LIBERO-PRO demonstrate that FIT-MAC achieves state-of-the-art performance under diverse perturbations and consistently improves success rate across multiple VLA backbones. The largest gains occur under position, task, and environment perturbations, while high success rates are maintained under object and semantic perturbations.
02 / MOTIVATION
A wrong object and a failed placement require different recovery decisions.
When the language-specified object is uncertain or inconsistent with the scene, rebind the target and regenerate the grounded prompt.
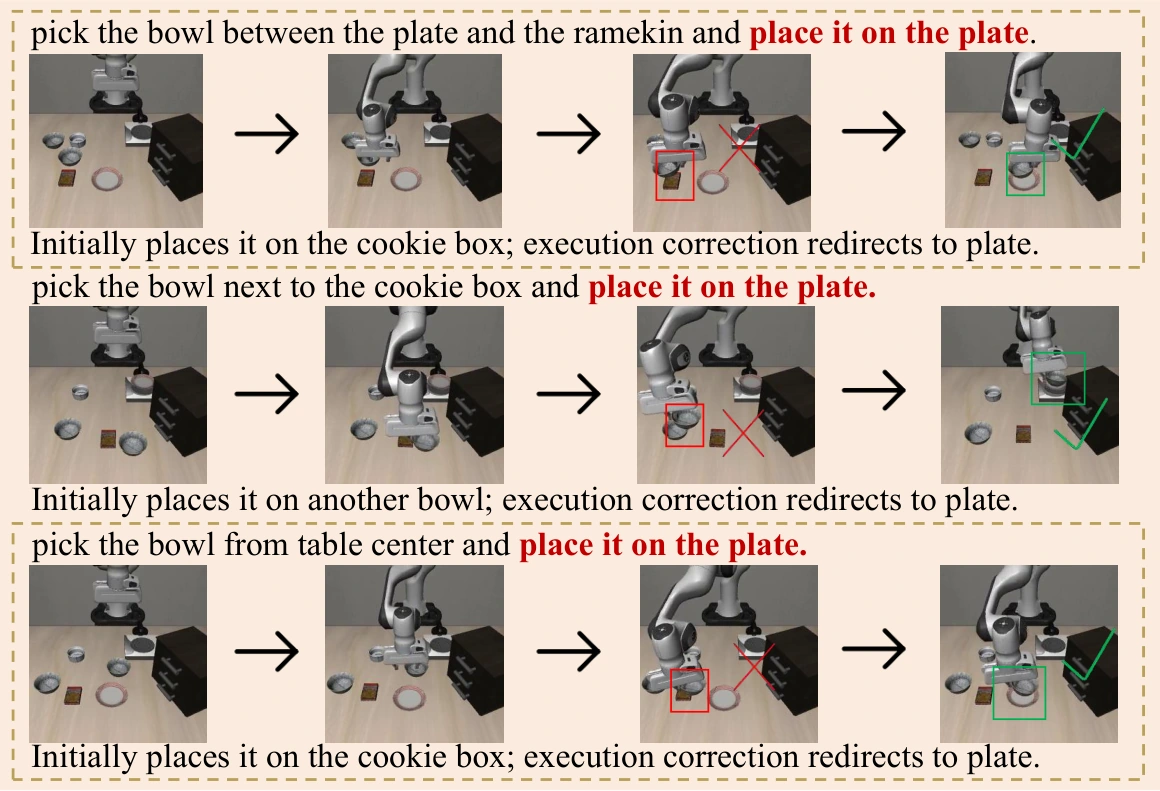
When grounding is correct but manipulation fails, retain the target lock and invoke bounded grasping or placement recovery.
The pretrained VLA remains the default action generator. Recovery changes inference-time control without updating policy parameters.
03 / HOW IT WORKS
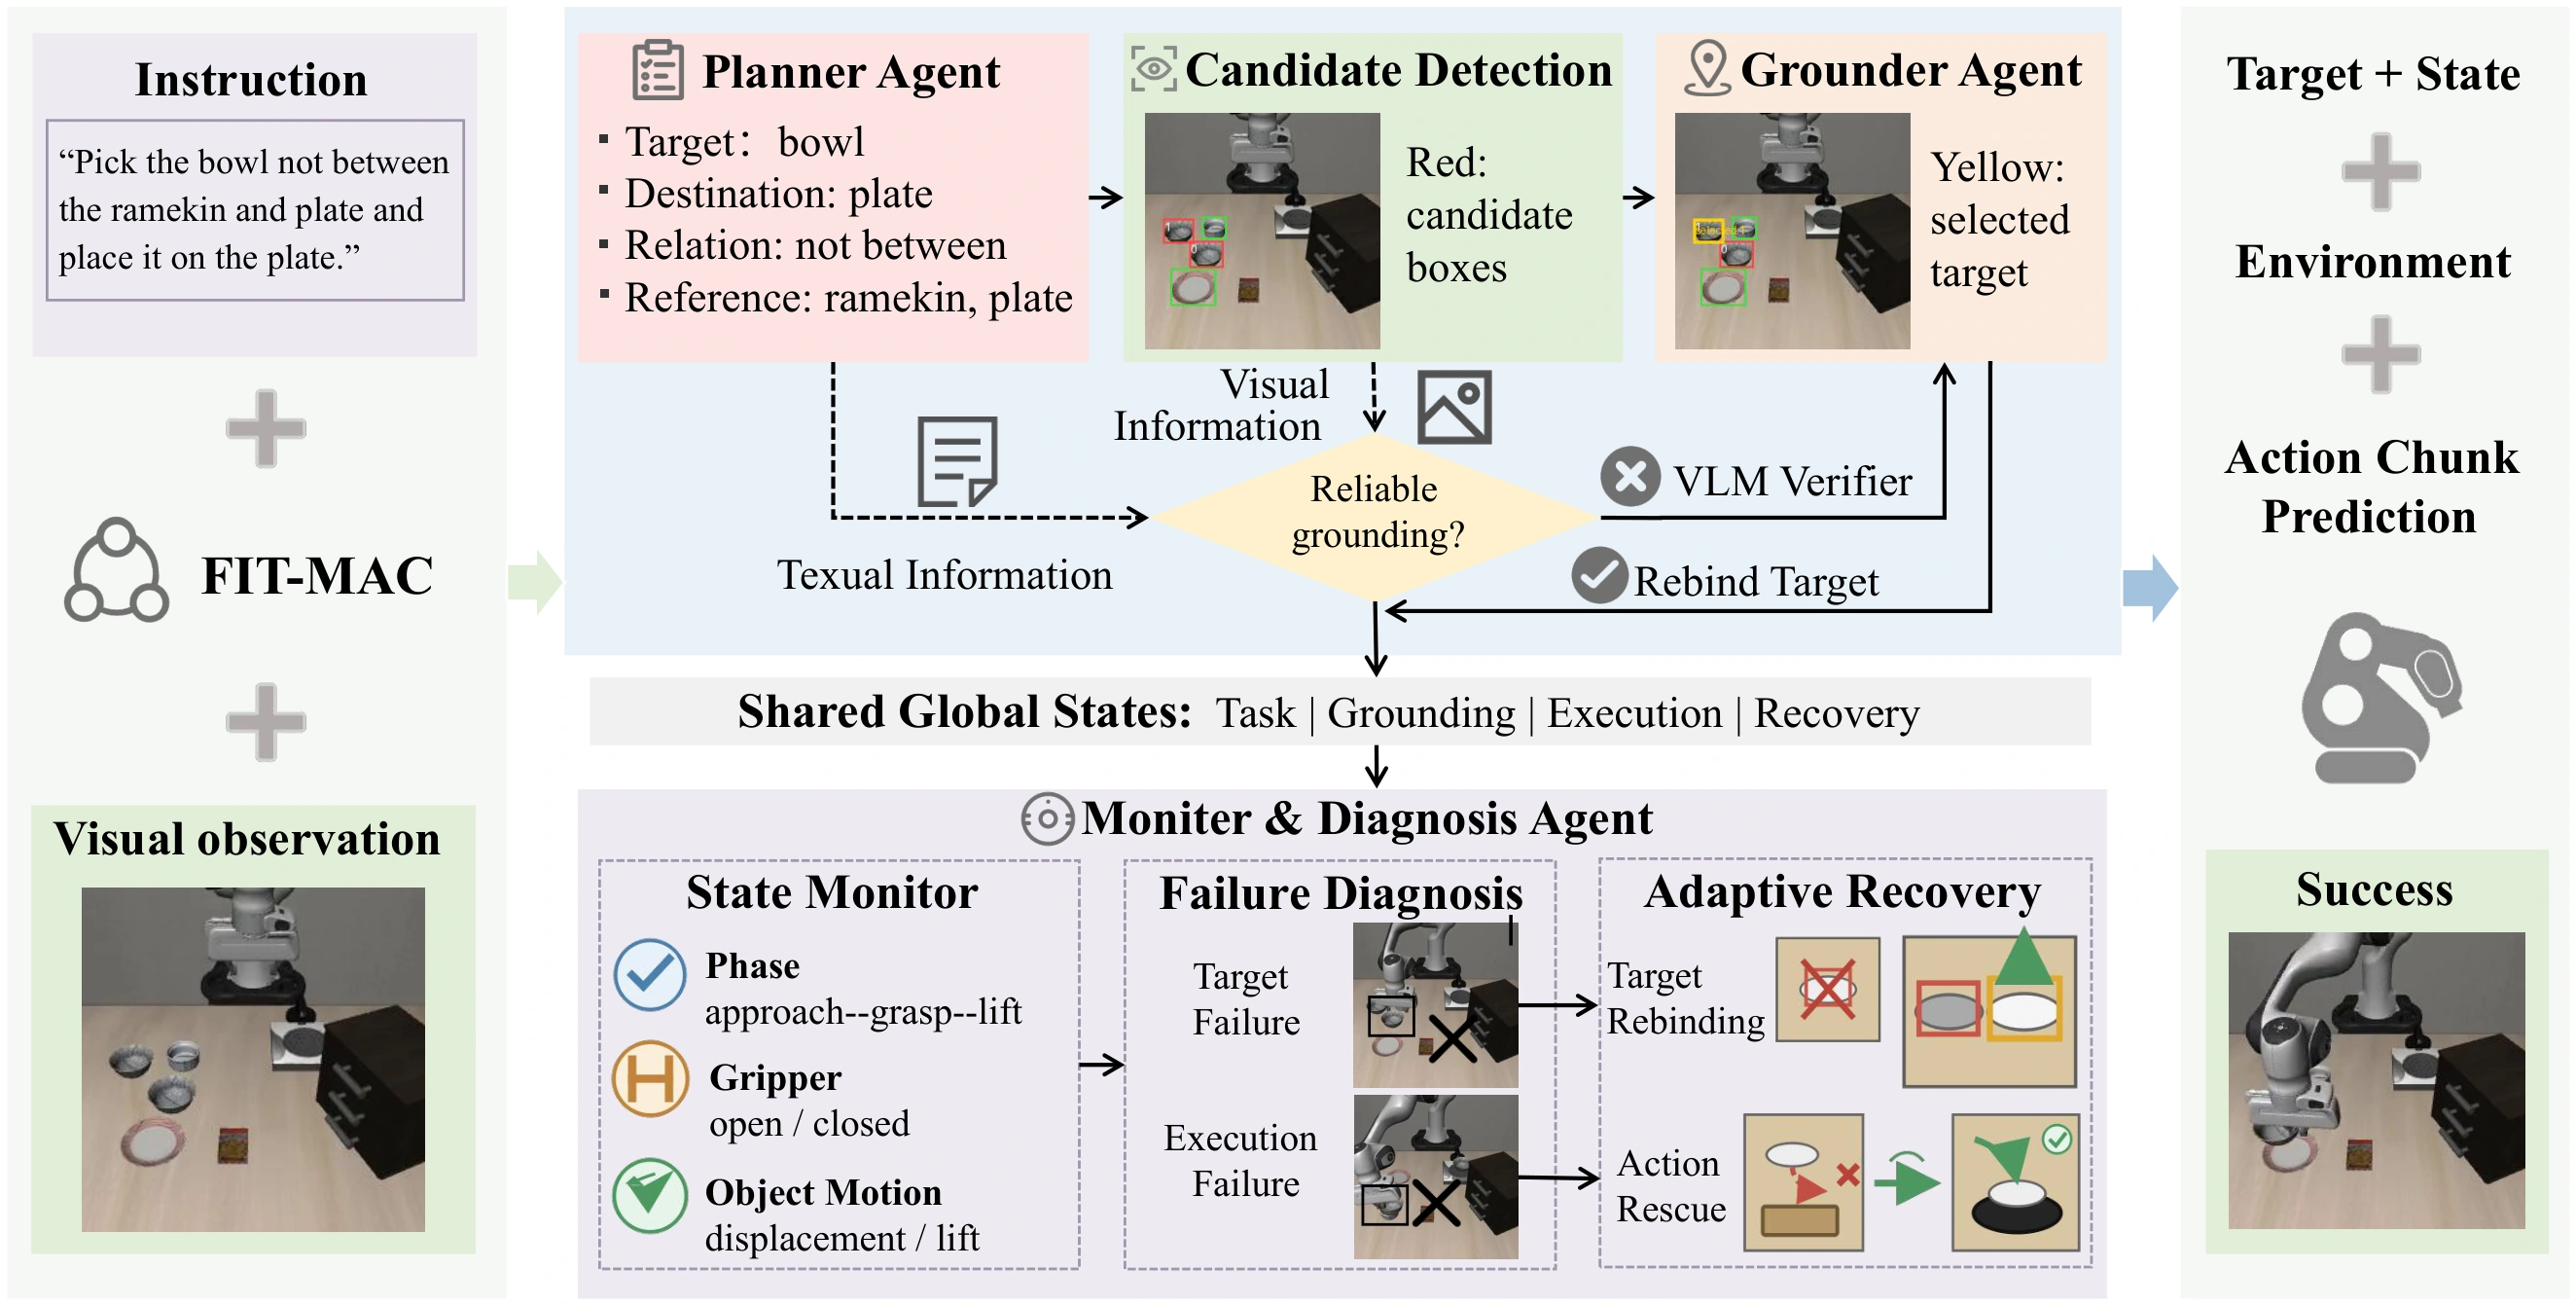
Extract targets, destinations, relations, and spatial constraints, then organize the instruction into bounded manipulation attempts.
Detect candidate objects and ground the instruction to a target. Use a VLM resolver when candidates are uncertain or ambiguous.
Track approach, grasp, lift, transport, placement, and release using geometric progress, gripper state, object motion, and timeout signals.
Rebind an unreliable target or invoke bounded local recovery for a physical execution failure. Otherwise, continue with the base VLA.
04 / DEMO
A dedicated space for the full demonstration video. The complete demo is coming soon.
05 / RECOVERY COMPARISON VIDEOS
Eight paired examples across target correction and execution recovery. Choose a case to compare its unsuccessful and successful rollouts.
TARGET BINDING
Recover from incorrect object selection by correcting the target binding.
Case 01 · Paired by the supplied case number.
Play pair starts both clips together. Each clip retains its original duration and stops at its final frame.
LOCAL EXECUTION
Recover from a manipulation or placement error after selecting the intended target.
Case 01 · Paired by the supplied case number.
Play pair starts both clips together. Each clip retains its original duration and stops at its final frame.
06 / EXPERIMENTS
LIBERO-PRO evaluation on LIBERO-Object and LIBERO-Spatial. Values below are reported in the supplied manuscript.
FIT-MAC average success rate
Gain over OpenVLA's 45.9%
Frozen VLA backbones evaluated
The main comparison covers ten settings: five perturbation types in each suite. OpenVLA and FIT-MAC use matched evaluation conditions; other methods use reported results. Evaluation protocol ↗
| Method | LIBERO-Object | LIBERO-Spatial | Avg. | ||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|
| Obj. | Pos. | Sem. | Task | Env. | Obj. | Pos. | Sem. | Task | Env. | ||
| MolmoAct | 92.0 | 6.0 | 96.0 | 0.0 | — | 90.0 | 0.0 | 88.0 | 0.0 | — | — |
| NORA | 86.0 | 0.0 | 92.0 | 0.0 | — | 92.0 | 0.0 | 91.0 | 0.0 | — | — |
| X-VLA | 89.0 | 2.0 | 98.0 | 8.0 | — | 97.0 | 0.0 | 96.0 | 0.0 | — | — |
| AtomVLA | 93.0 | 10.0 | 99.0 | 0.0 | — | 95.0 | 16.0 | 95.0 | 1.0 | — | — |
| CaP-Agent₀ | — | 22.0 | — | 18.0 | — | — | 12.0 | — | 14.0 | — | — |
| RATs | — | 61.0 | — | 63.0 | — | — | 29.0 | — | 31.0 | — | — |
| OpenVLA | 98.0 | 0.0 | 98.0 | 0.0 | 0.0 | 97.0 | 0.0 | 77.0 | 0.0 | 89.0 | 45.9 |
| FIT-MAC (Ours) | 99.0 | 93.4 | 98.8 | 87.2 | 48.8 | 97.2 | 40.2 | 86.8 | 37.8 | 97.8 | 78.7 |
Success rate (%). Obj. = object identity; Pos. = object position; Sem. = semantic binding; Task = task instruction; Env. = environment. — indicates unreported results. The overall average is shown only for methods evaluated on all ten settings.
Average success rate over five perturbation types per suite (Figure 4).
Improvements are absolute percentage-point gains.
| Perturbation | LIBERO-Object | LIBERO-Spatial | ||||
|---|---|---|---|---|---|---|
| SR (%) | IR (%) | RSR (%) | SR (%) | IR (%) | RSR (%) | |
| Obj. | 99.0 | 99.8 | 99.3 | 97.2 | 37.8 | 97.9 |
| Pos. | 93.4 | 99.5 | 93.8 | 40.2 | 87.6 | 41.3 |
| Sem. | 98.8 | 98.9 | 99.6 | 86.8 | 42.8 | 98.6 |
| Task | 87.2 | 100.0 | 87.1 | 37.8 | 90.6 | 35.5 |
| Env. | 48.8 | 50.4 | 97.5 | 97.8 | 21.2 | 99.1 |
SR: success among all evaluated episodes. IR: fraction of episodes with at least one intervention. RSR: success among intervened episodes. Values are transcribed as reported in Table 2.
07 / ABLATIONS
Controlled ablations with the OpenVLA backbone reveal the contribution of each recovery component.
| Configuration | Success rate (%) | ΔSR (pp) | |||
|---|---|---|---|---|---|
| Object | Spatial | Avg. | Object | Spatial | |
| FIT-MAC | 85.4 | 72.0 | 78.7 | 0.0 | 0.0 |
| w/o target correction | 77.2 | 69.8 | 73.5 | -8.2 | -2.2 |
| w/o execution correction | 47.0 | 62.4 | 54.7 | -38.4 | -9.6 |
| w/o hard pick | 50.2 | 70.0 | 60.1 | -35.2 | -2.0 |
| w/o hard place | 63.2 | 64.0 | 63.6 | -22.2 | -8.0 |
Success rate (%) and change relative to full FIT-MAC in percentage points. Object and Spatial are averages over five perturbation types.
Removing execution correction lowers average success from 78.7% to 54.7%. Target correction, hard-pick recovery, and hard-place recovery also contribute to performance.
| Parameter | Values | Object (%) | Spatial (%) | Avg. (%) |
|---|---|---|---|---|
| Failure threshold | 2 / 3 / 4 | 85.4 / 85.4 / 85.4 | 70.8 / 70.6 / 70.6 | 78.1 / 78.0 / 78.0 |
| Confidence threshold | 0.10 / 0.12 / 0.18 | 85.4 / 85.4 / 85.4 | 71.0 / 70.6 / 71.0 | 78.2 / 78.0 / 78.2 |
| Minimum rescue step | 8 / 12 / 16 | 85.4 / 85.4 / 85.4 | 71.2 / 70.6 / 71.0 | 78.3 / 78.0 / 78.2 |
| Execution horizon | 1 / 2 / 3 | 68.0 / 85.4 / 87.4 | 72.0 / 70.0 / 69.8 | 70.0 / 77.7 / 78.6 |
Values appear in the same order across each row. Bold parameter values are the manuscript defaults. Each row reproduces its own reported evaluation setting.